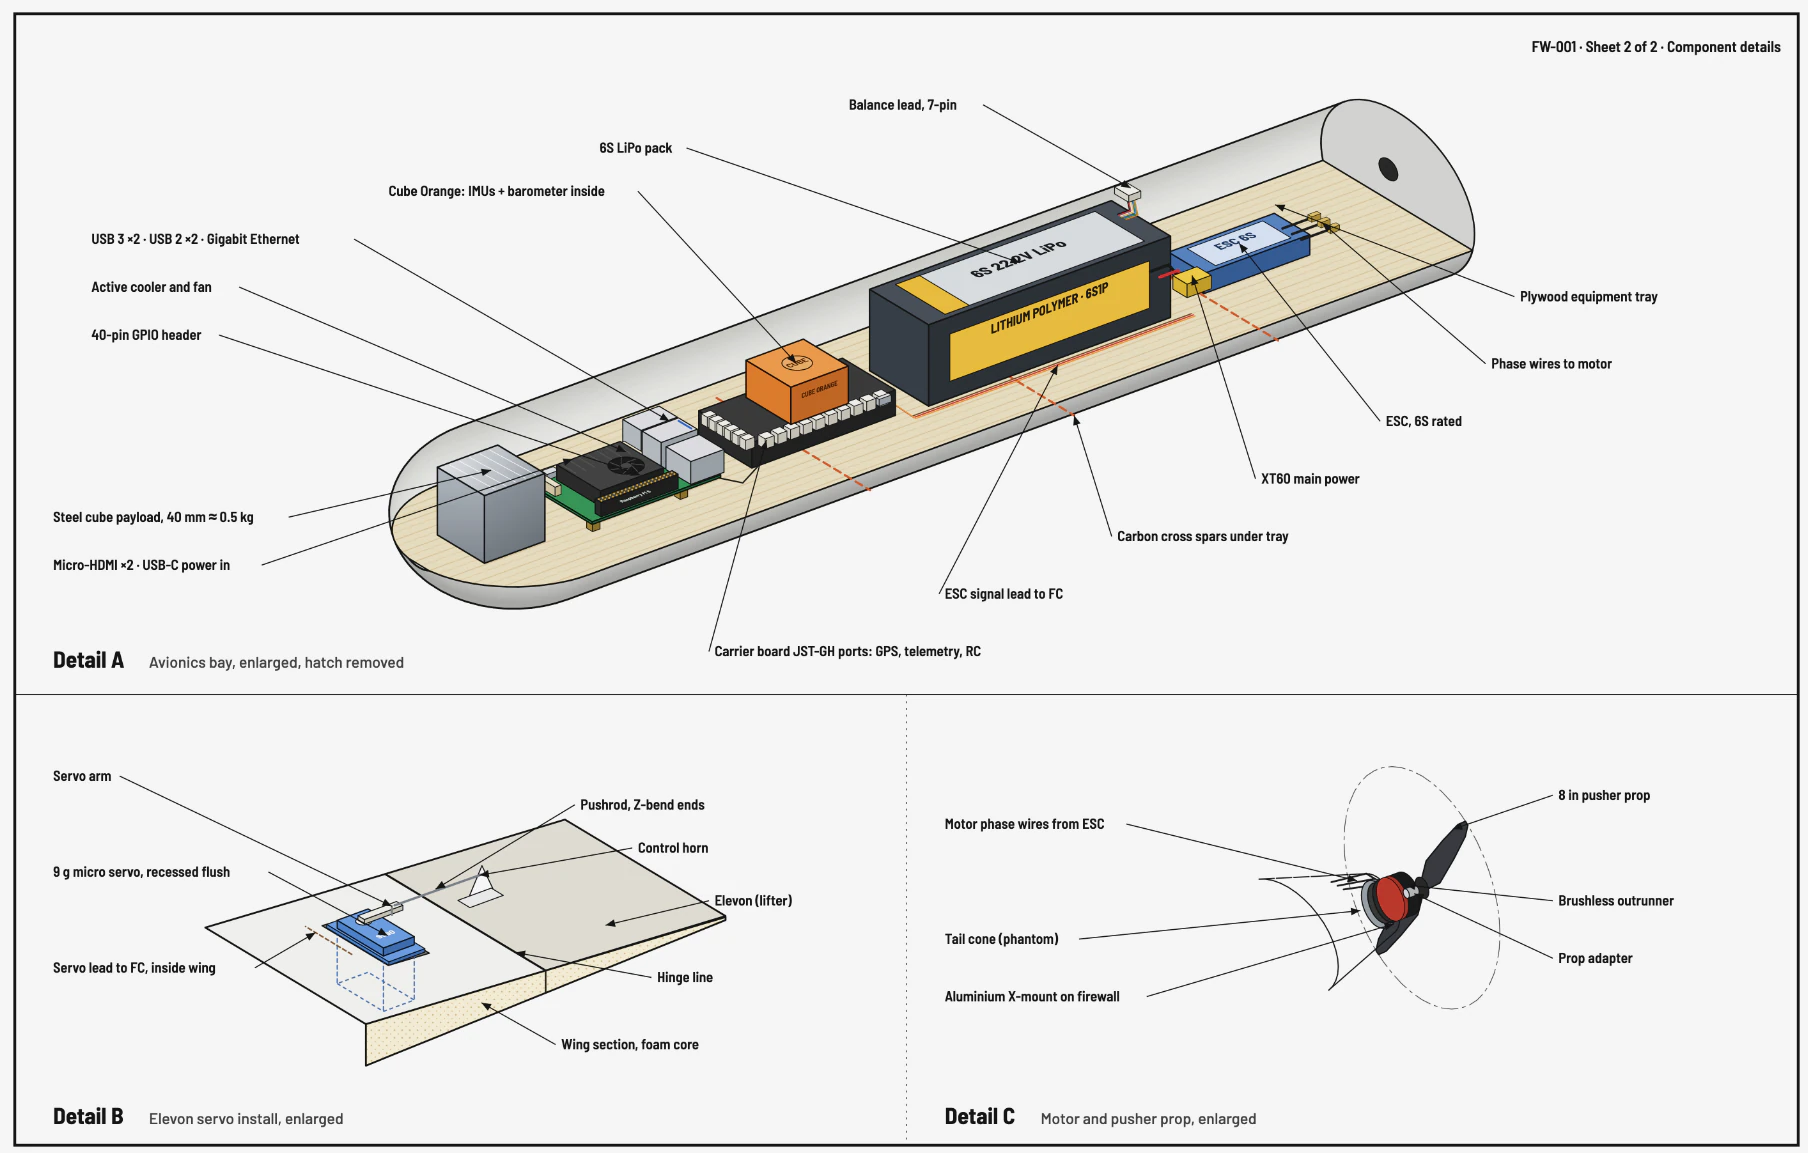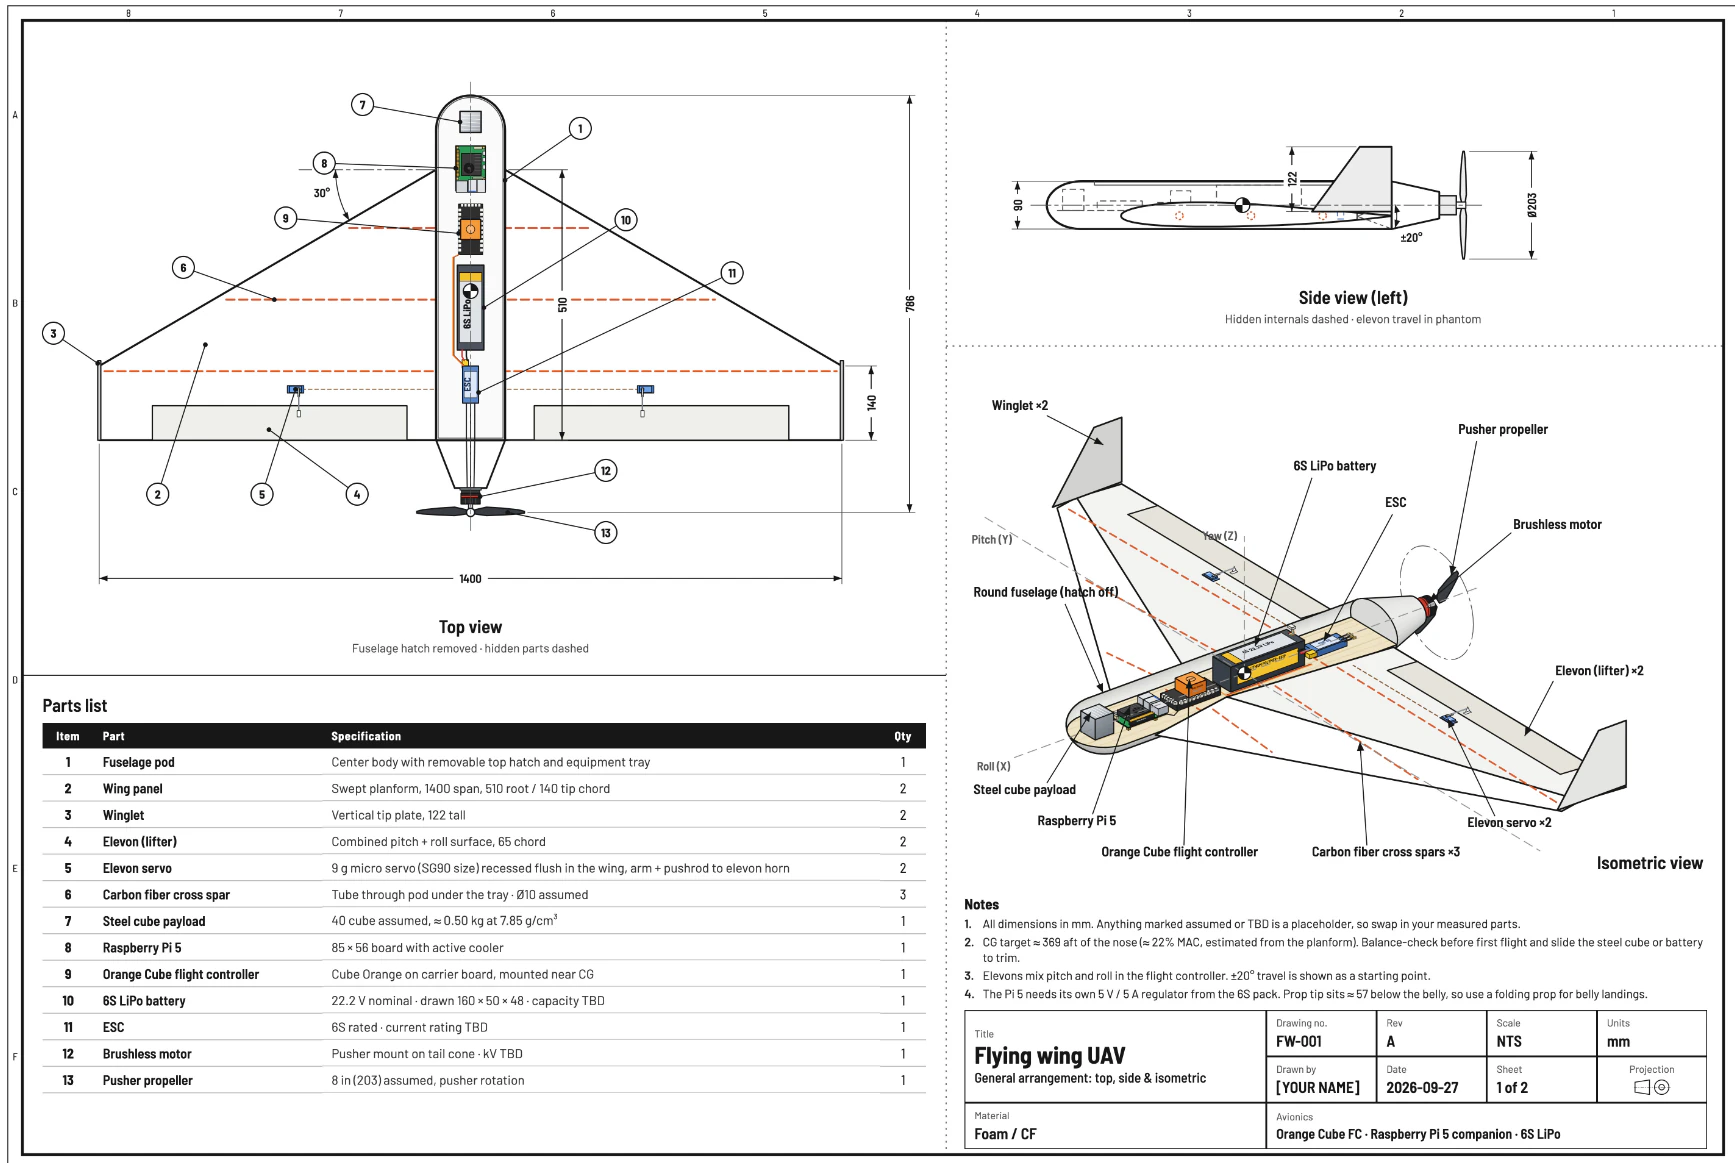
A 3D-printed interceptor is launched at an inbound drone and has to find it, hold it and close on it using its own camera. I'm building the software that does that.
What I'm building
- Tracking and guidance: computer vision on the interceptor's camera that locks onto the target and steers the intercept in real time.
- Training and evaluation: the pipeline behind the detector. Our dataset is about 65,000 images and pairs the target with what it must not fire on: birds, airliners and other drones. Real-footage results are reported apart from synthetic renders.
- Sensor fusion: several ground sensor feeds merged into one track and handed to the onboard seeker.
- Embedded Linux on the flight computer: camera drivers, process management and the ground-station link.